Earlier Robotics Work
Pre-Ph.D. projects at CUHK, Shenzhen (2018–2020).
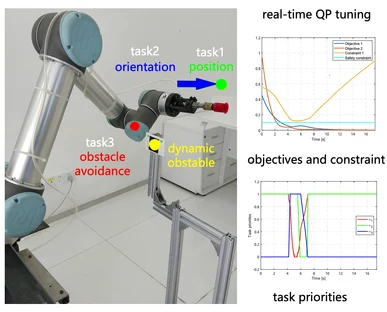
Real-time Task-Priority Control
Developed QP-based soft task-priority tuning for UR5 manipulation in dynamic environments.
Project & code/Video
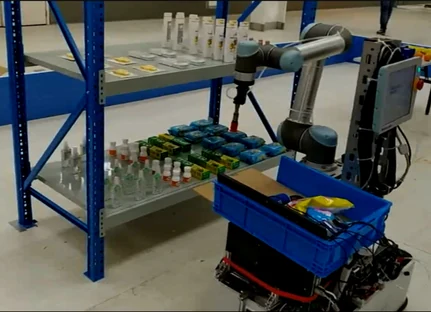
Warehouse Mobile Manipulation
Contributed to a team-built mobile manipulation system with RGB-D perception, navigation, and suction picking.
Project & code/Video
Related publication: Sample-efficient learning of soft priorities for safe control with constrained Bayesian optimization · IRC 2020.
Service & Teaching
Reviewer: CVPR, ECCV, NeurIPS, ICLR, and CoRL.
Teaching assistant at HKUST: The Rise of Autonomous Robots; Deep Learning in Computer Vision.
Best Teaching Assistant Award, ECE, HKUST (2020–21).
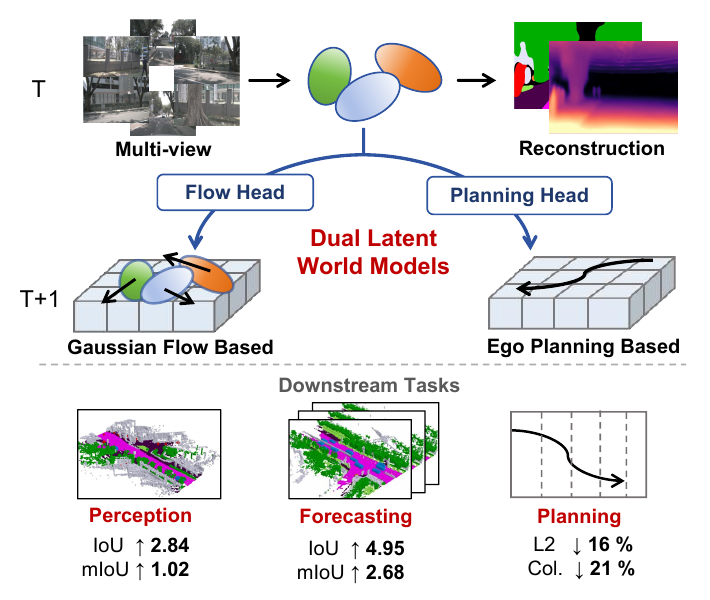 DLWM